 |
||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||||
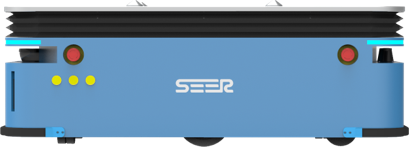
Mobile Control Robot SJV-W1000
|


|
Basic parameters |
|
|
|
Navigation method |
Laser SLAM |
|
|
Drive mode |
Two-wheel differential |
|
|
Shell color |
Blue / Customized color |
|
|
L*W*H |
1224*730*420mm |
|
|
Rotation diameter |
1350mm |
|
|
Weight (with battery) |
250kg |
|
|
Load capacity |
1000kg |
|
|
Chassis ground clearance |
25mm |
|
|
Jacking platform dimensions |
1200*700mm |
|
|
Maximum jacking height |
60±2mm |
|
|
jacking time |
8±0.5s |
|
|
Laser scanning height |
267mm |
|
|
Network |
Ethernet / Wi-Fi 802.11 a/b/g/n/ac |
|
|
Ambient temperature and humidity range |
TEMP: 0-50℃ / RH: 10-90%, no compression, no condensation |
|
|
IP rating[1] |
IP20 |
|
|
Passability (slope/step/gap)[2] |
≤5%/5mm/30mm |
|
|
Performance parameters |
|
|
|
Minimum passable width |
850mm |
|
|
Navigation position accuracy[3] |
±5mm |
|
|
Navigation angle accuracy[3] |
±0.5° |
|
|
Navigation speed |
≤ 1.6m/s |
|
|
Map area (single frame) |
≤ 400000m² |
|
|
Battery specifications |
48/42 (Lithium Iron Phosphate)V/Ah |
|
|
Battery parameters |
|
|
|
Comprehensive battery life |
8h |
|
|
Charging time (10-80%) |
≤1.5h |
|
|
Charging method |
Manual/Automatic |
|
|
Battery cycle number |
> 2000 |
|
|
Lidar number |
2(SICK nanoScan3 / P+F R2000-HD + OLEI LR-1BS2) |
|
|
Configurations |
|
|
|
Number of low-position obstacle avoidance photoelectric |
× |
|
|
Cargo detection |
× |
|
|
E-stop button |
√ |
|
|
Speaker |
√ |
|
|
Atmosphere light |
√ |
|
|
Bumper strip |
√ |
|
|
Features |
|
|
|
Basic functions[4] |
√ |
|
|
Wi-Fi roaming |
√ |
|
|
Automatic charging[5] |
√ |
|
|
Shelf recognition |
√ |
|
|
Spin[6] |
× |
|
|
Precise location with QR code[7] |
〇 |
|
|
QR code navigation[8] |
〇 |
|
|
Laser reflector navigation |
〇 |
|
|
Certifications |
|
|
|
EMC/ESD |
√ |
|
|
UN38.3 |
√ |
|
|
RoHS |
√ |
|
|
REACH |
√ |
|
Figures: √ Supported X Not supported 〇 Optional
The road surface should be smooth, clean and free of obvious ups and downs. Slope 5% = arctan (0.05) ≈ 2.8°. The robot must not stop or turn at the ramps, steps, or gaps, but can pass quickly perpendicular to them.
The localization accuracy is affected by environment, ground, etc. Please refer to the localization accuracy interpretation in the final technical agreement.
Basic functions include but are not limited to map editing, model editing, localization module, navigation module and API interface.
Need to be used with a dedicated automatic charging pile.
SJV-W1000 is designed for indoor transportation only and is not recommended for outdoor use.
Seers group is a professional autonomous forklift company, we provide agv reach truck, amr forklift and etc. Want to know more? Contact us.
Contact : Gong Miya, 400 726 9969
Good deal: buying from seller
We invite you to read our terms of use. You can also visit our FAQ section and see our information section on the risks associated with counterfeiting.
|
This page is about importers and exporters of Mobile Control Robot SJV-W1000 Search in a category : B2B Services Search in a category : control, robot, w1000, mobile |
 999077 Audio and Video
Report abuse
Thursday, August 01, 2013
Quantity : moq:1pcs - Price : USD5074.9
Along with the XF300, the XF305 Professional Camcorder represents Canon 's entry into professional solid state video acquisition. Following on the heels of its widely respected XH line of tape-based camcorders, the XF305 takes advantage of the latest HD technology--along with Canon's...
AC Electronic Ltd
- 999077 - HongKong
- +85 2 23 25 18 67
- +86 13501567844
999077 Equipment goodsReport abuse
Tuesday, September 22, 2026
Unitronics Vision130 PLC+HMI OPLC – Automate Control Engineering Ltd. (winston@automate-ace.com) Vision130.Connects! PLC, HMI & onboard I/Os plus ETHERNET, SMS/GPRS, CANopen, MODBUS... The Vision130.is a palm-sized PLC with a built-in Operator Panel. The panel offers a graphic...
Automate Control Engineering Ltd.
- automatehk
- 999077 - Hong Kong
- +85 2 23 42 72 76
 20152 Vehicles
Report abuse
Thursday, April 02, 2015
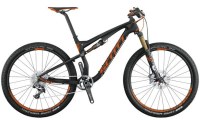
SPECIFICATION : Frame Spark Carbon / IMP technology / HMX / BB92 / Carbon swingarm with 160PM U-Mono Link / Tapered Headtube IDS SL dropouts for 142 × 12mm BB height adj. Travel Front 120mm Rear 120 - 85 - Climb / Shock 190 × 50 Fork FOX 32 Float Factory CTD Air / Kashima...
INDOBIKESPORT
- 20152 - Medan - Sumatera Utara
- +628994498351